Pick a robot. Change one thing. Keep your version.
Build the body. Share the skills.
Your ideas. In motion.
Try MK Play →Get early access ↓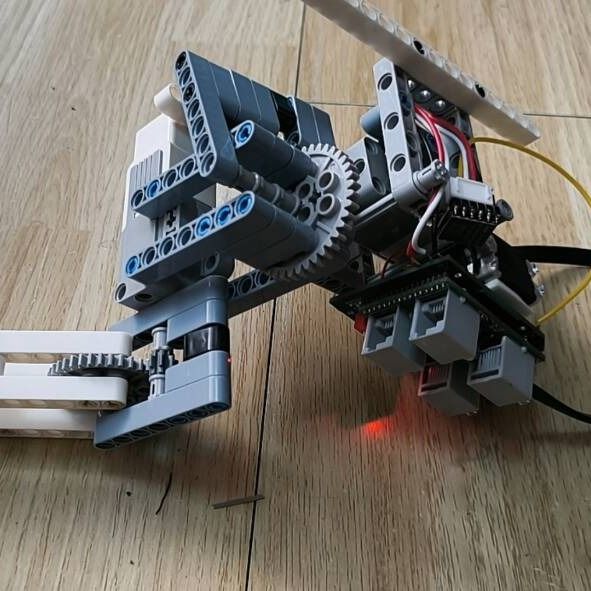
Body · Brain · Skill
Three things make a robot you can play with, change and keep.
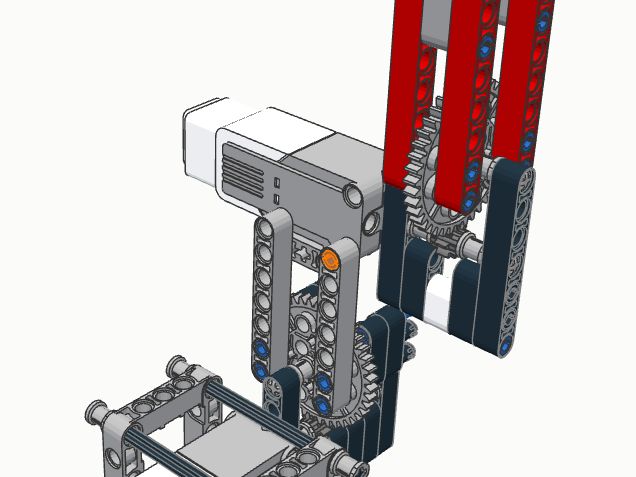
Start from a body that already works.
The build page shows one part per step, with captions and voice. Two people can build the two halves at the same time. Then change one thing: a longer leg, a different foot.
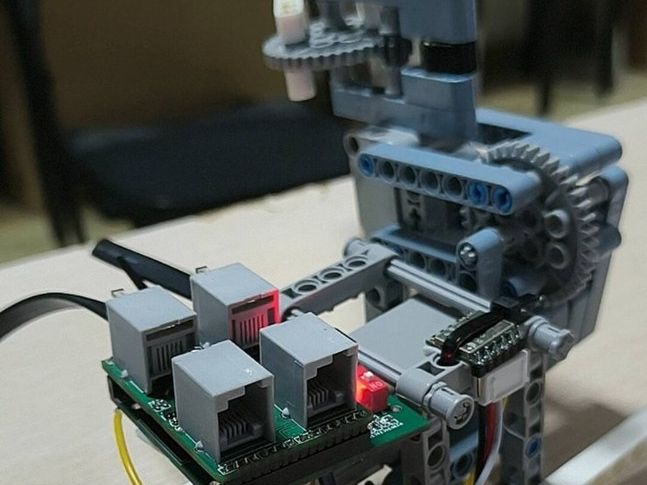
MK Brain runs it.
MK Brain drives the motors, reads motor angles and sensor feedback, and runs the program. Match the connectors and power, connect MK Brain, and you can start controlling the motors.
Try it, watch it, change it, keep it.
A robot skill packages something the robot can do with the code, setup, and conditions it needs.
An engineer reads the same three as shape, electronics and software. Your prototype is what you hand over: how the body is built, how the brain is connected, what the skill does, and what was tried.
One robot, five days
- Oct 23 · We asked for a new robot that can get up by itself.
- Oct 25 · The generated body was built for real.
- Oct 28 · It stood up on MK Brain, running a small network trained in simulation.
It does not get up every time yet. On Nov 16–17 it tried 17 times on the real robot and held standing once. Next: from single motions to skills you can share.
What the robot wrote down
The same parts, other bodies
The same joints, rebuilt. Each card says honestly how far it has got.
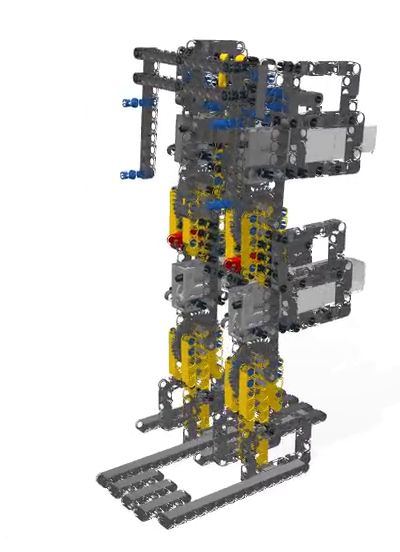 Two-legged robot
Four motors. Designed and tested in simulation. It has not walked yet.
Moves in simulation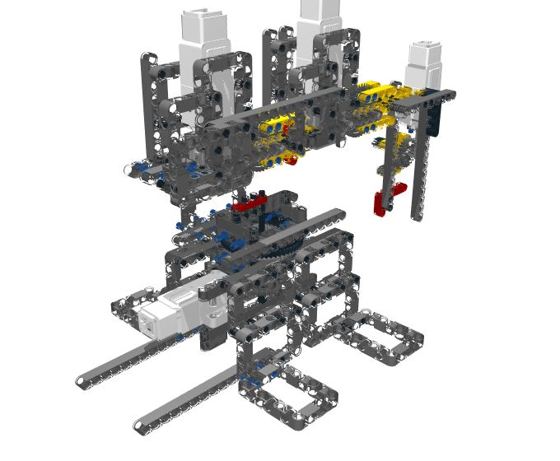 An arm from leg parts
The parts of one leg, laid out as an arm with a turntable and a gripper. Computer design only: not built on a real robot yet.
Computer design onlyNext: other families
Every way a robot moves fits into a few families: turn, swing, push, lift, walk. These are design previews. None has been built for real yet.
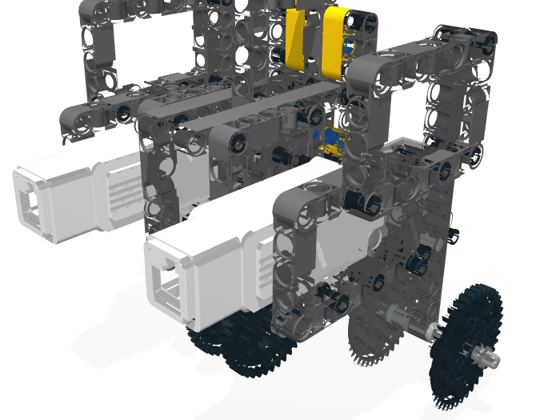 Two-wheel car
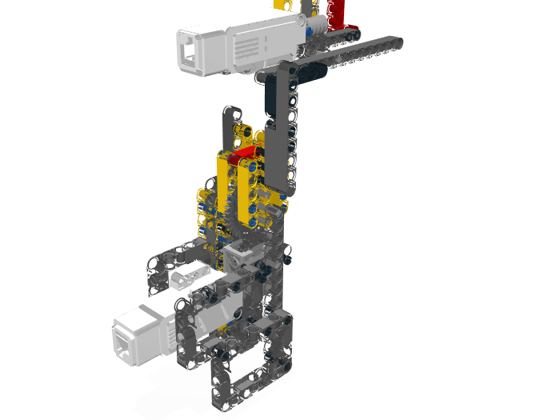 Claw
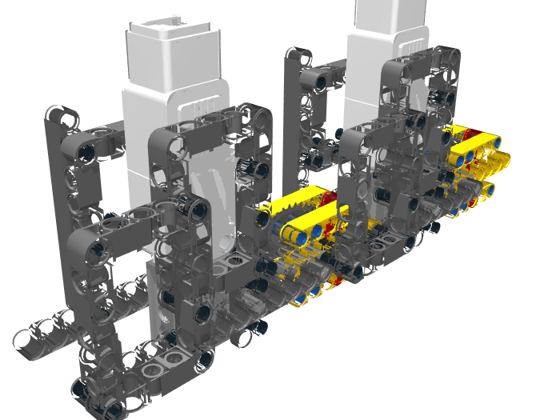 Crawler
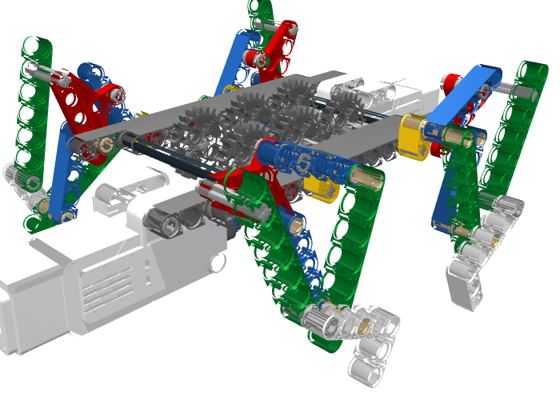 Linkage walker
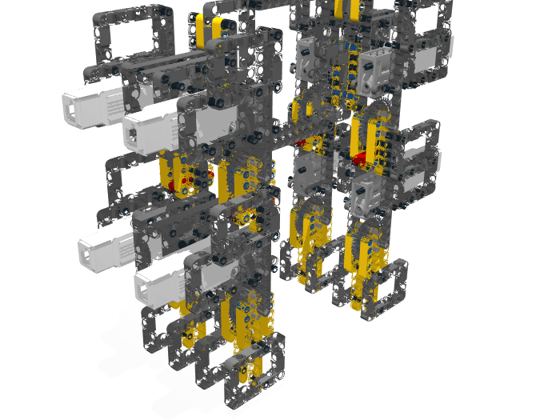 Four legs
 Snake, on wheels
Be first to get the box
We are getting ready to crowdfund the first box. Leave your email and we will write when it opens. Nothing else.
Have a real task?
For now we are starting with kits. If your team has a concrete task, tell us about it; project work is something we plan to offer later.
Talk to us →